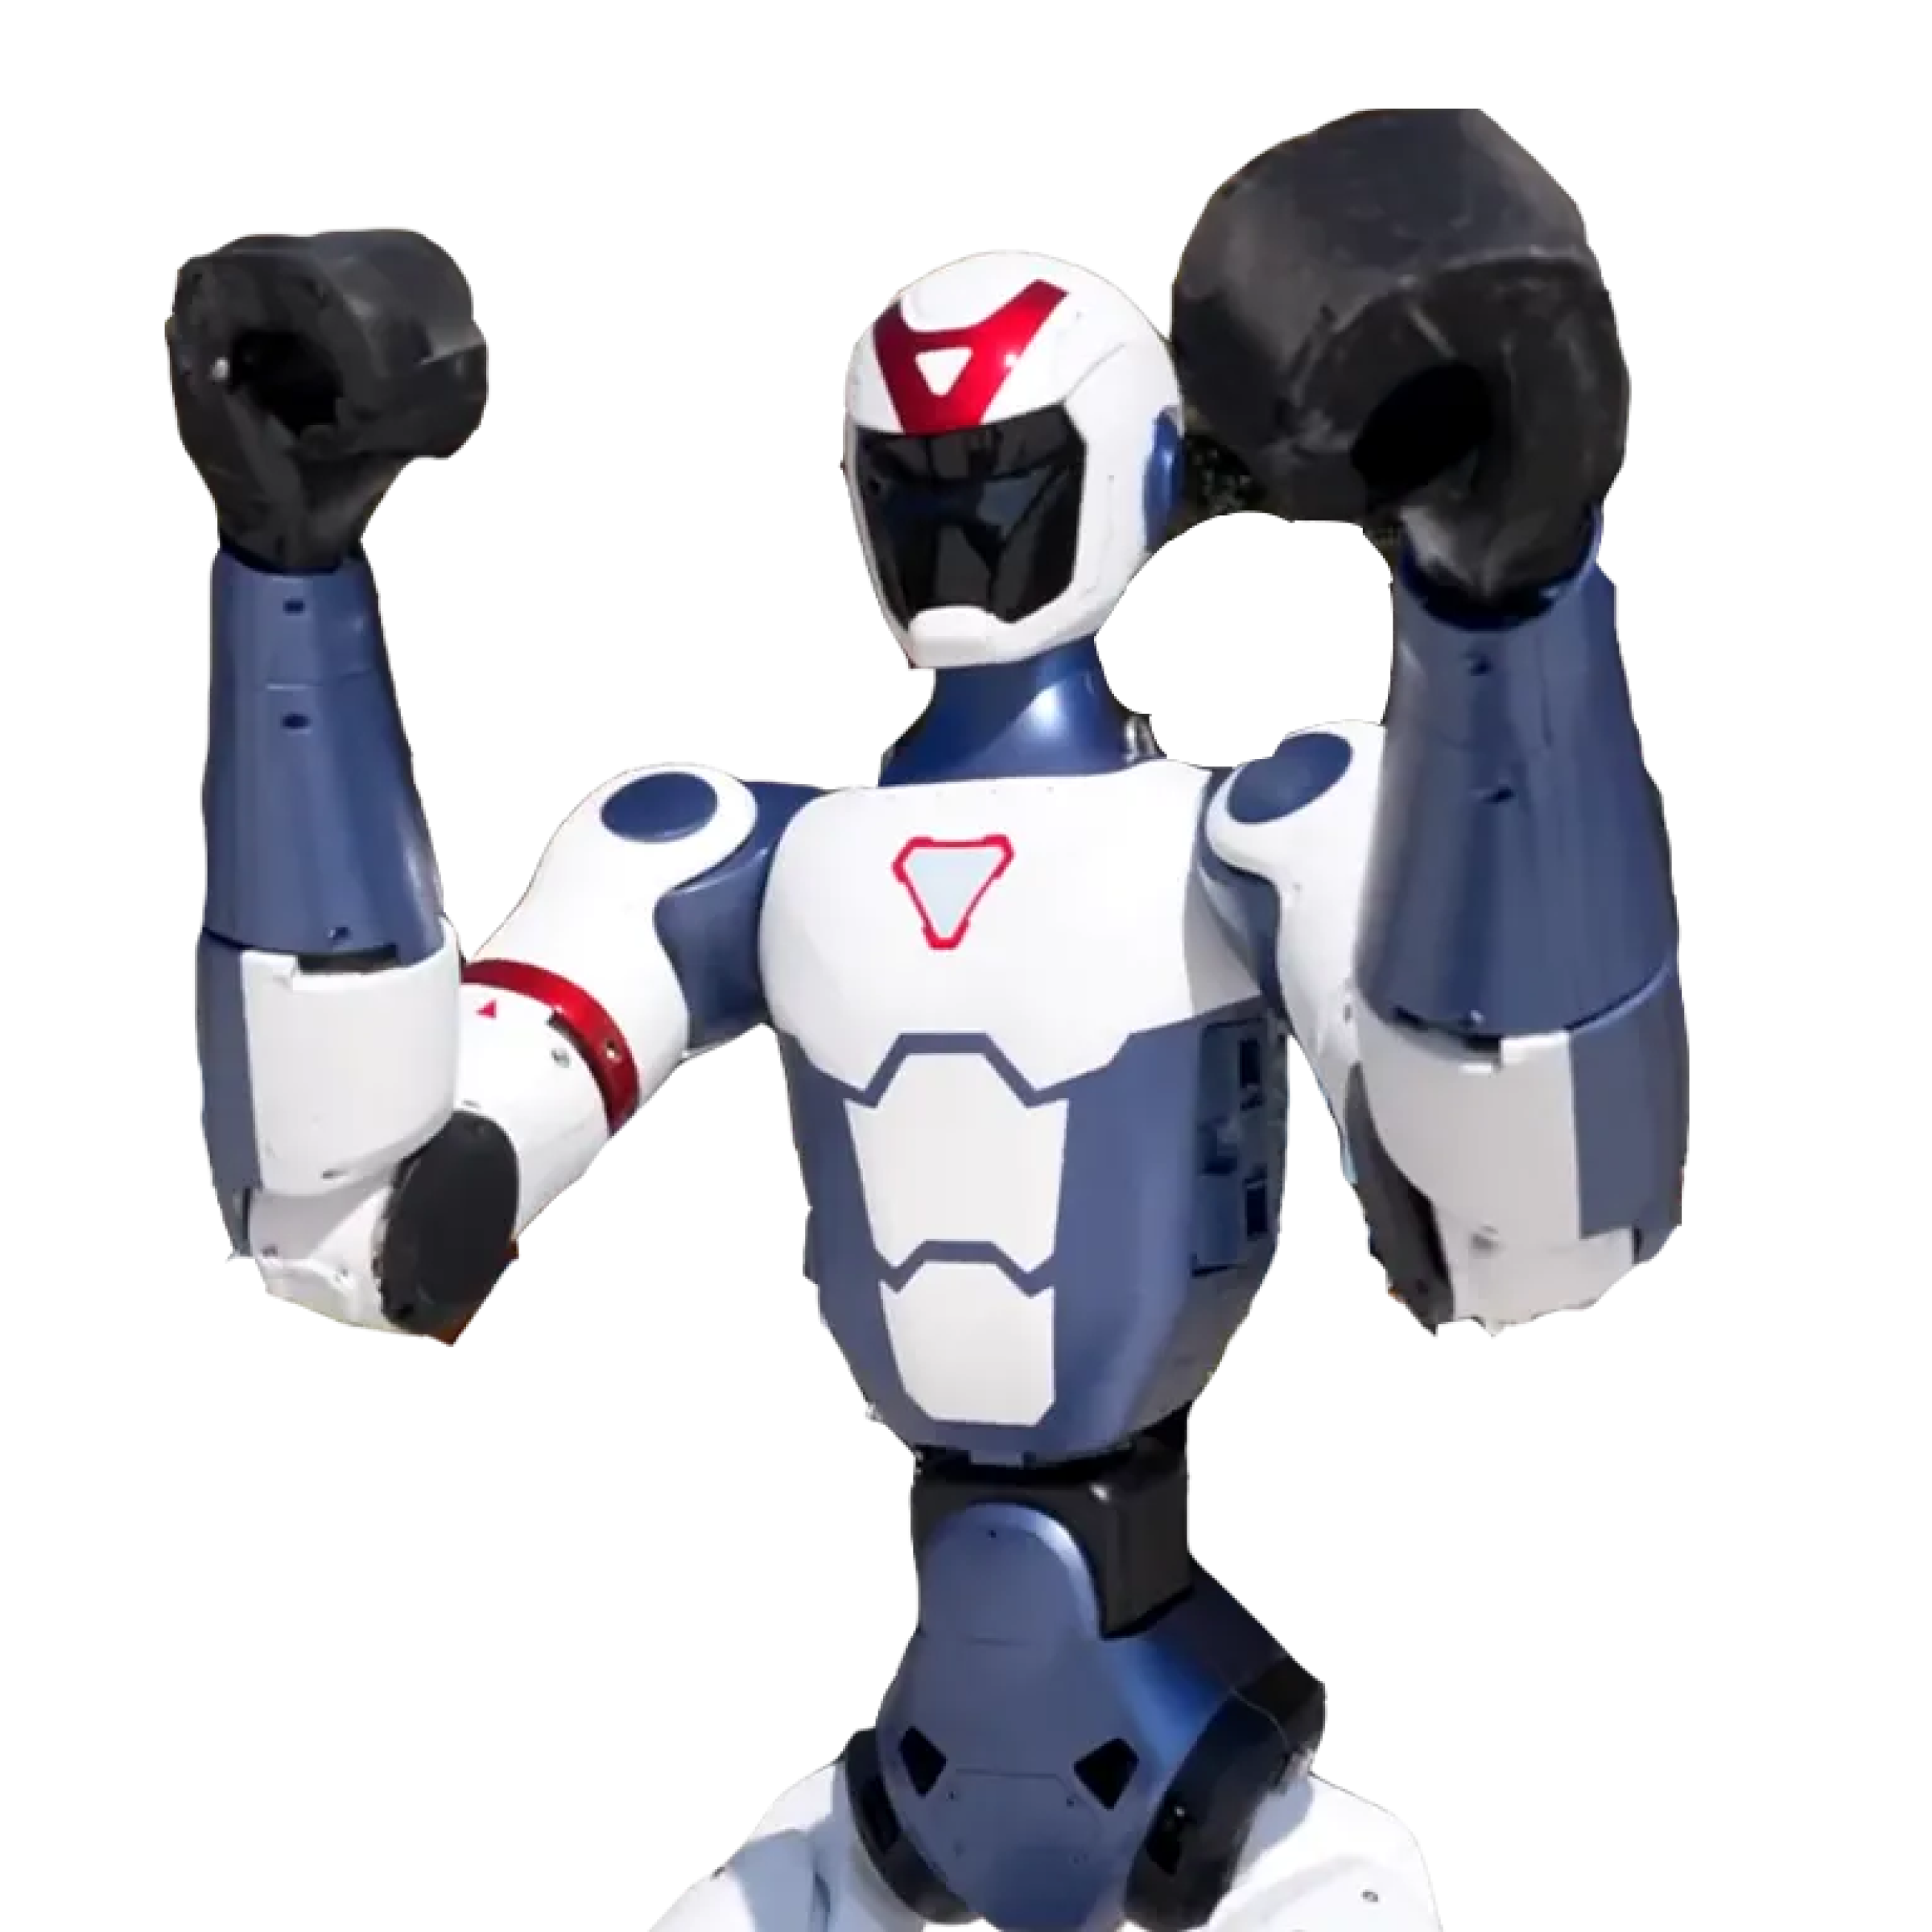

An R1 robot for research can support controlled work in bipedal locomotion, perception, motion planning, manipulation, interaction, and embodied intelligence. The strongest programs pair the right configuration with clear experimental goals, repeatable procedures, appropriate software access, and well-defined safety constraints. Toborlife AI, the official partner of Unitree, provides useful context on R1 research variants, compute, hand options, development access, support, and the practical limits teams should understand before deployment.