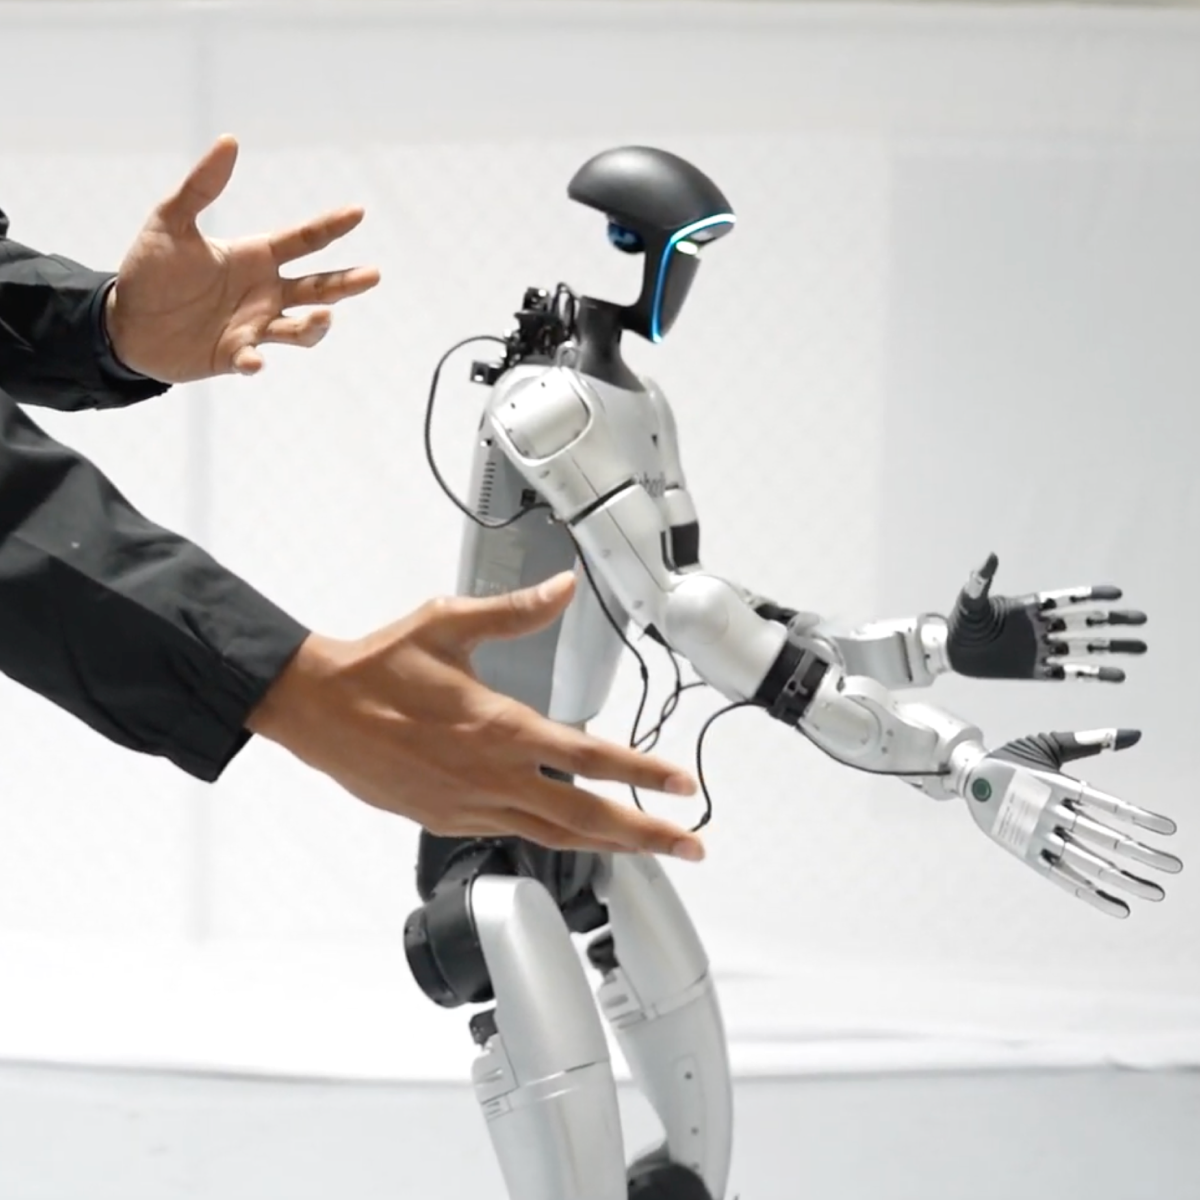

This bookmark explains why a remote control robot should be evaluated by task fit, feedback, recovery, and operating simplicity. It distinguishes basic driving or mode control from richer teleoperation workflows. Save it for teams deciding whether a controller, XR interface, or custom control setup best supports navigation, inspection, manipulation, or supervised robotics testing. Use it as a neutral reference note for bookmarking, categorization, and quick editorial review.