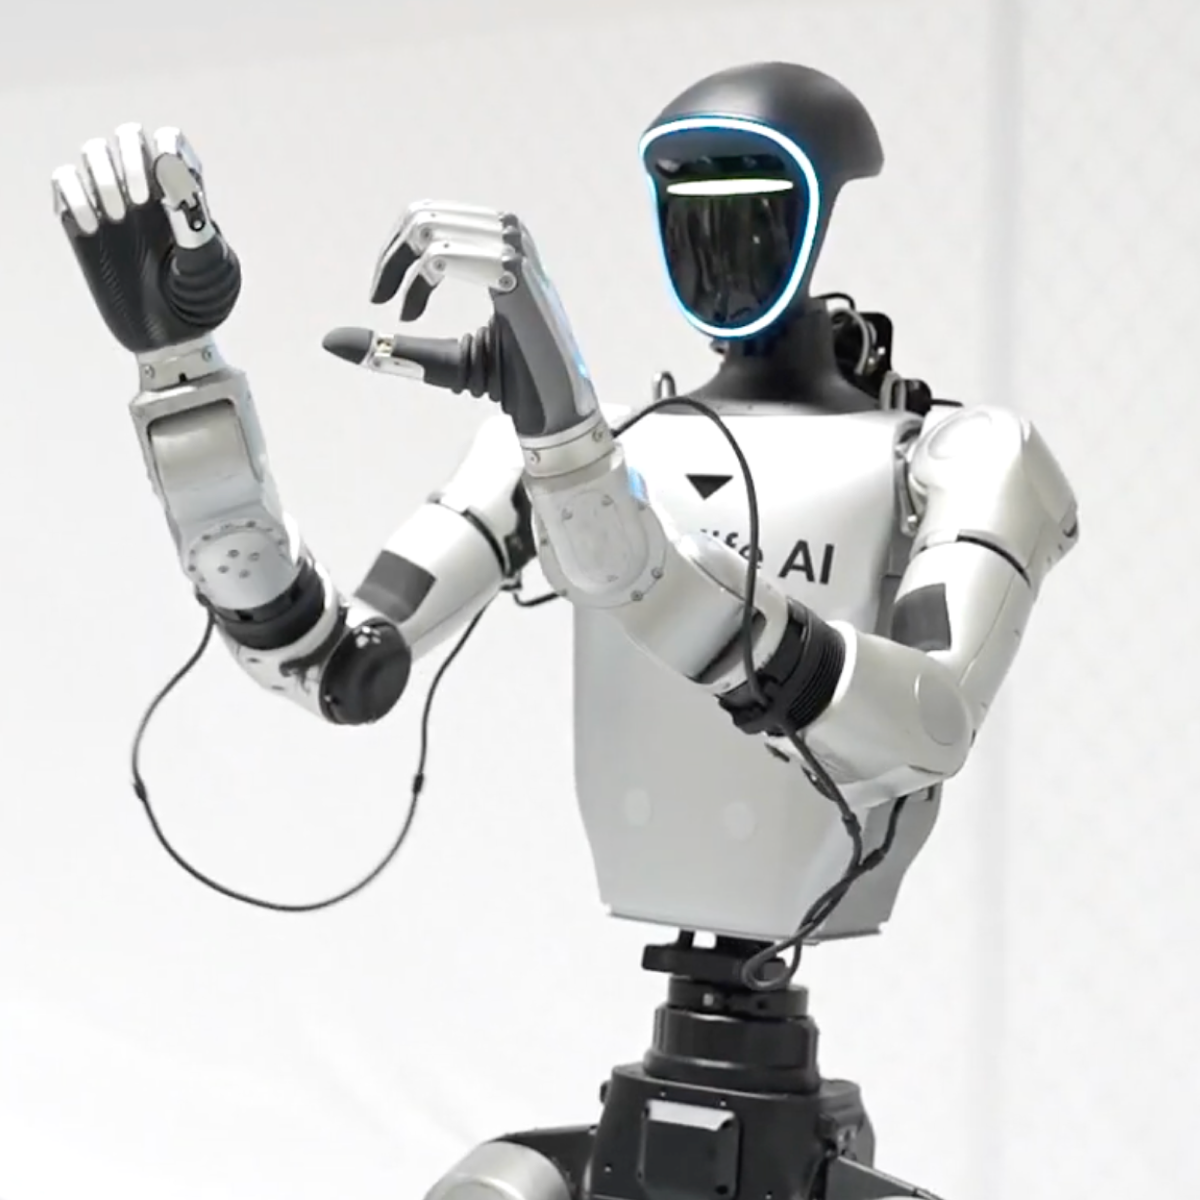

This resource frames Unitree robot teleoperation as a repeatable workflow for control, feedback, safety, recovery, and data. It is useful for teams comparing humanoid and quadruped operation modes across research, inspection, education, and physical AI development. Bookmark it when the goal is to turn robot time into cleaner demonstrations and more useful records. Use it as a neutral reference note for bookmarking, categorization, and quick editorial review.