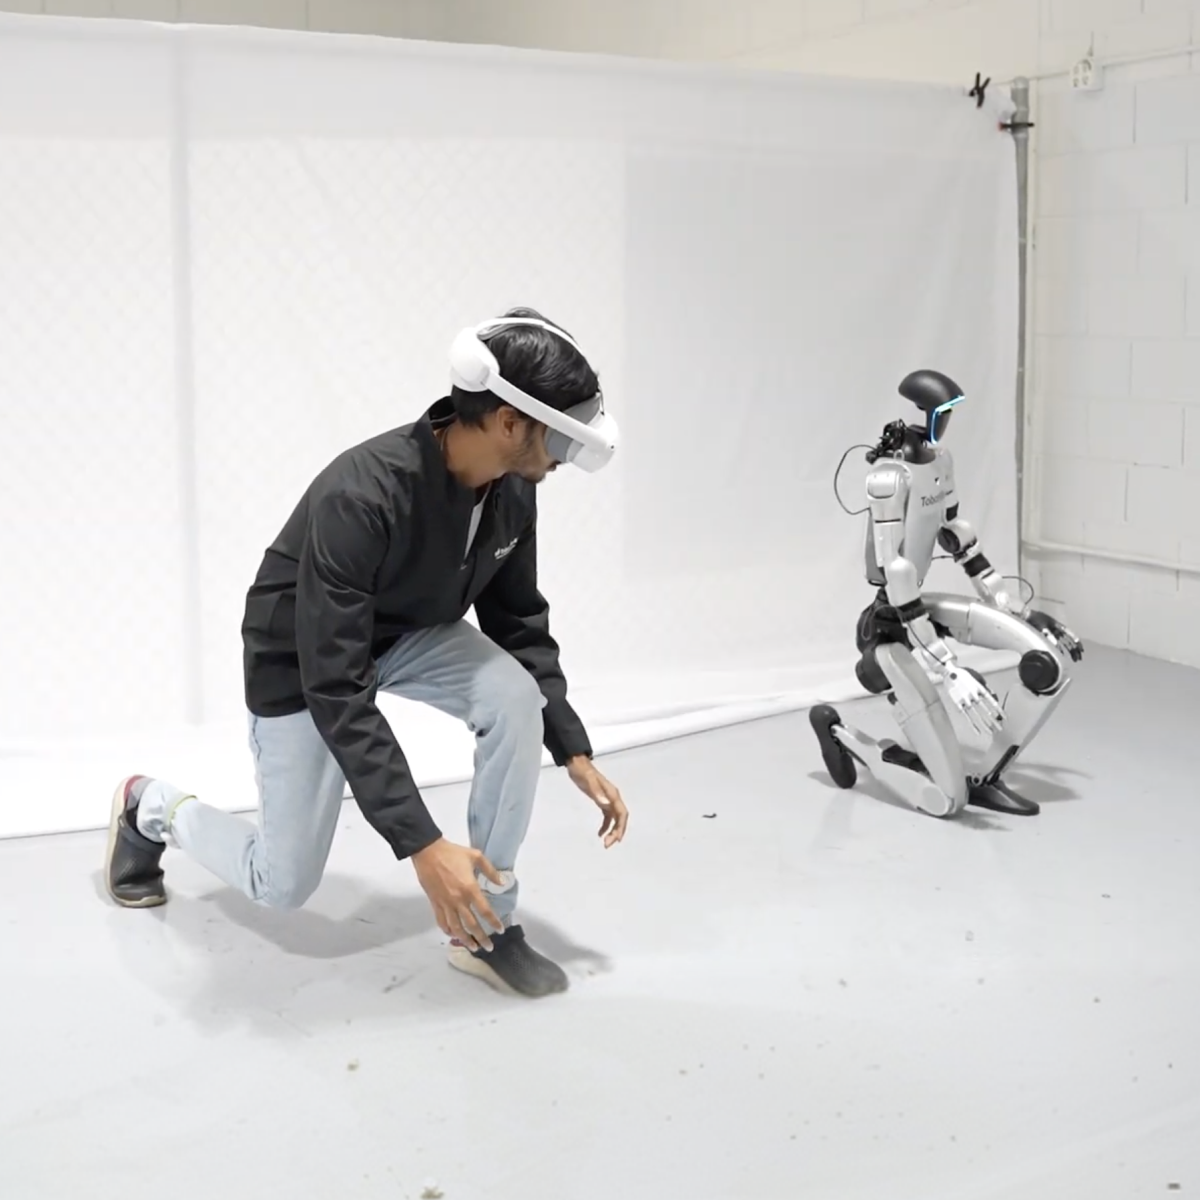

Save this bookmark for understanding Unitree humanoid teleoperation as a whole-body control problem. It covers posture, balance, hand motion, operator feedback, synchronization, data recording, and recovery. Useful for labs comparing G1, H2, or R1 workflows where teleoperation must support coordinated movement, manipulation, and repeatable data collection. It also supports cleaner planning, internal review, and non-promotional sharing across bookmarking platforms and directories.