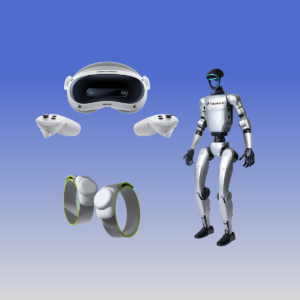
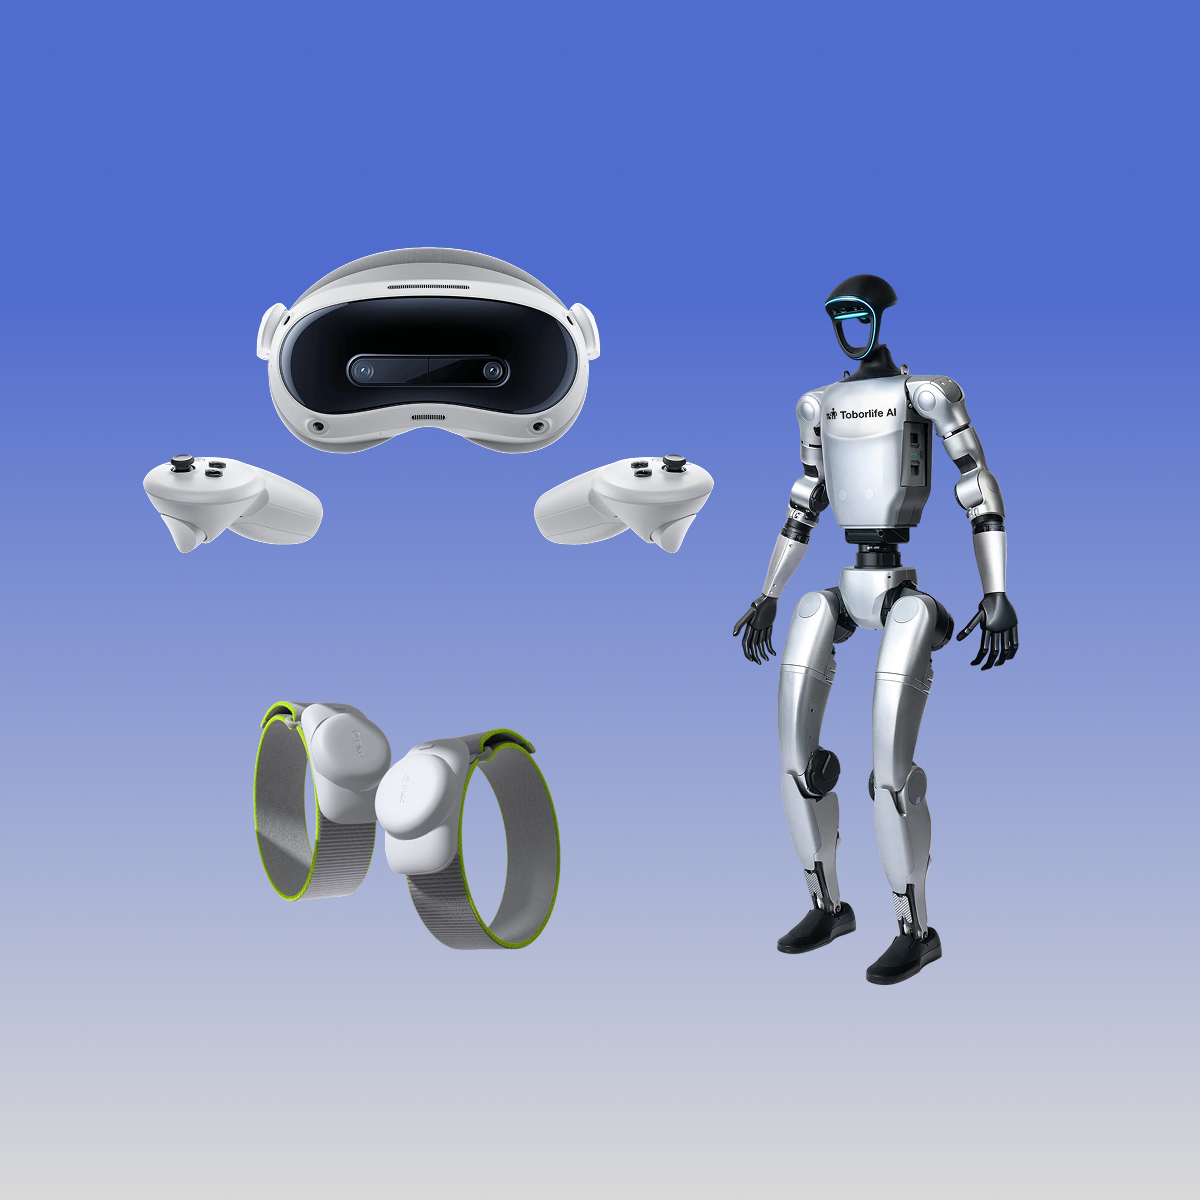

Save this guide for evaluating Unitree h2 teleoperation in human-scale robotics research. It explains why larger reach, workspace impact, safety boundaries, recovery, and operator awareness matter more when teleoperation moves to a full-size humanoid. Useful for labs comparing H2 control workflows, XR interfaces, sensing layouts, and data-collection strategies. It gives reviewers concise context for saving, tagging, indexing, and sharing the resource responsibly.