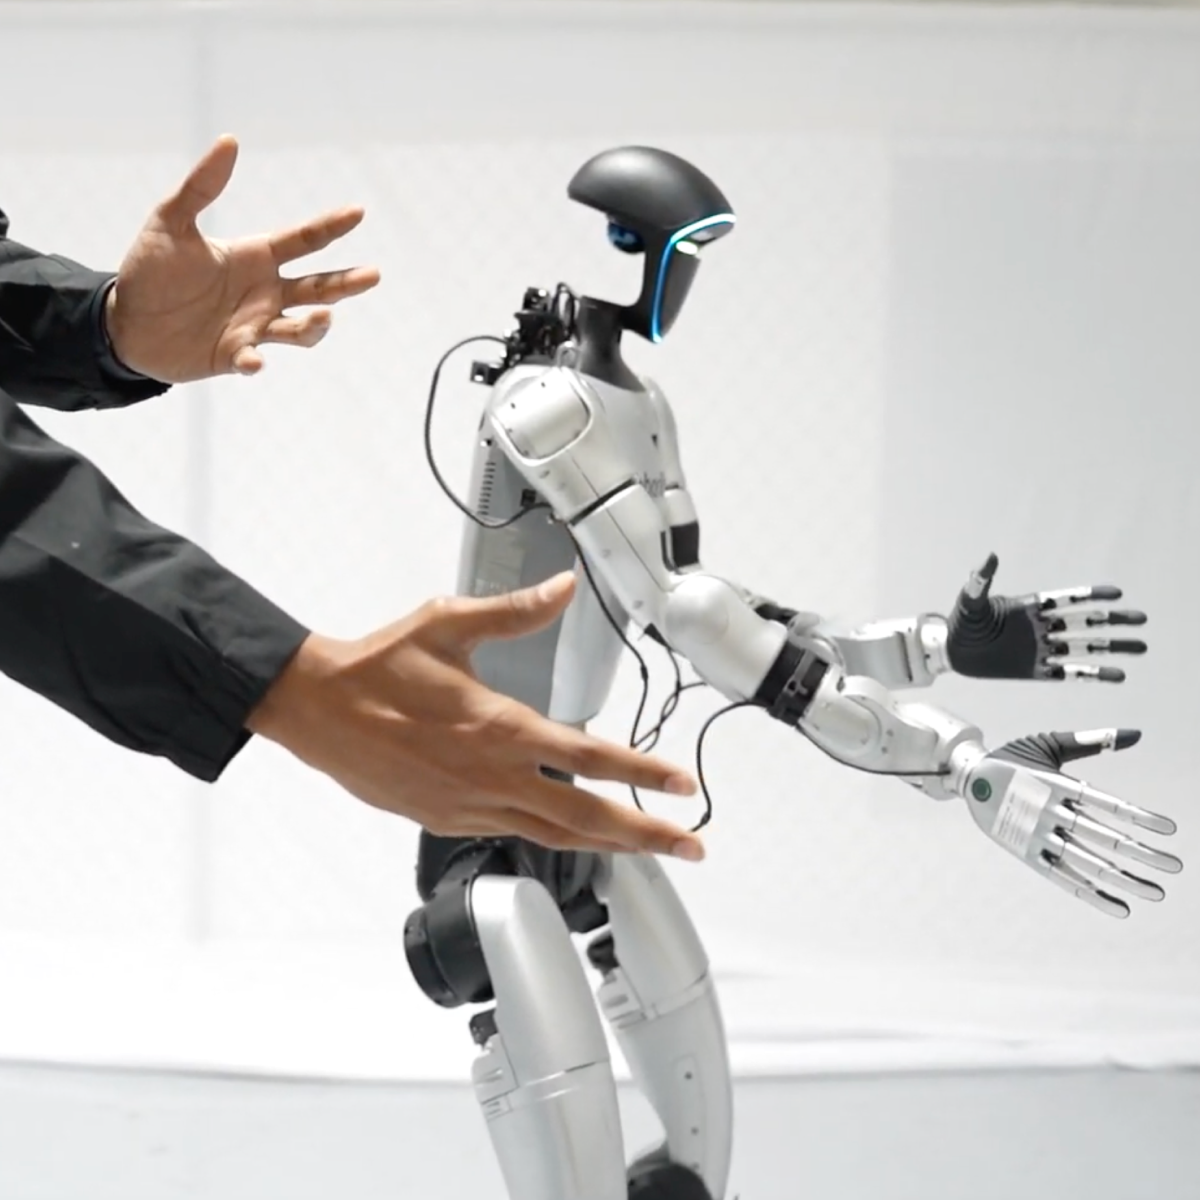

Save this resource for understanding how a teleoperation robot workflow should be judged by control quality, operator feedback, data capture, latency, recovery, and repeatability. It is useful for researchers and developers comparing remote operation systems where the goal is not only movement, but also usable demonstrations, training data, and interpretable session records. It also supports cleaner planning, internal review, and non-promotional sharing across bookmarking platforms and directories.