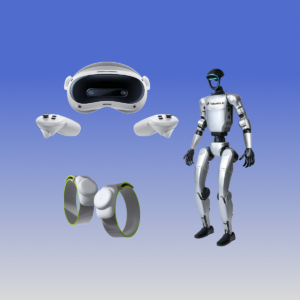
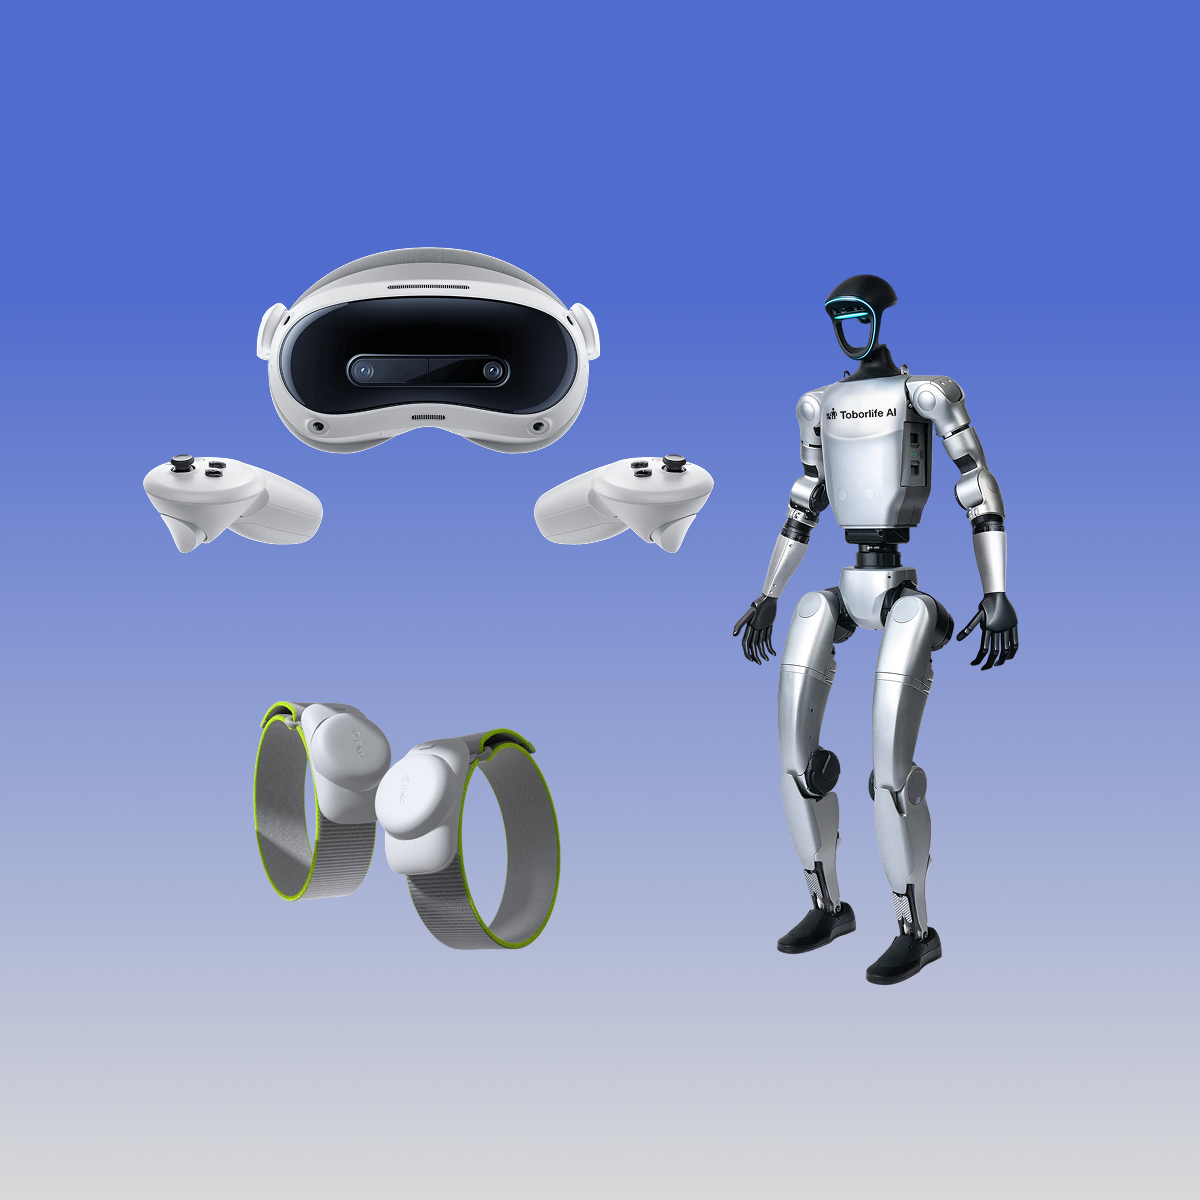

This resource helps teams compare Unitree XR teleoperation with custom control approaches for humanoid robots. It highlights operator immersion, hand or controller input, setup burden, recording workflow, calibration, and robot compatibility. Bookmark it for labs deciding whether XR provides a practical path to repeated demonstrations, cleaner data, and faster teleoperation setup. Use it to support clearer categorization, faster review, and context-rich sharing on bookmarking platforms.