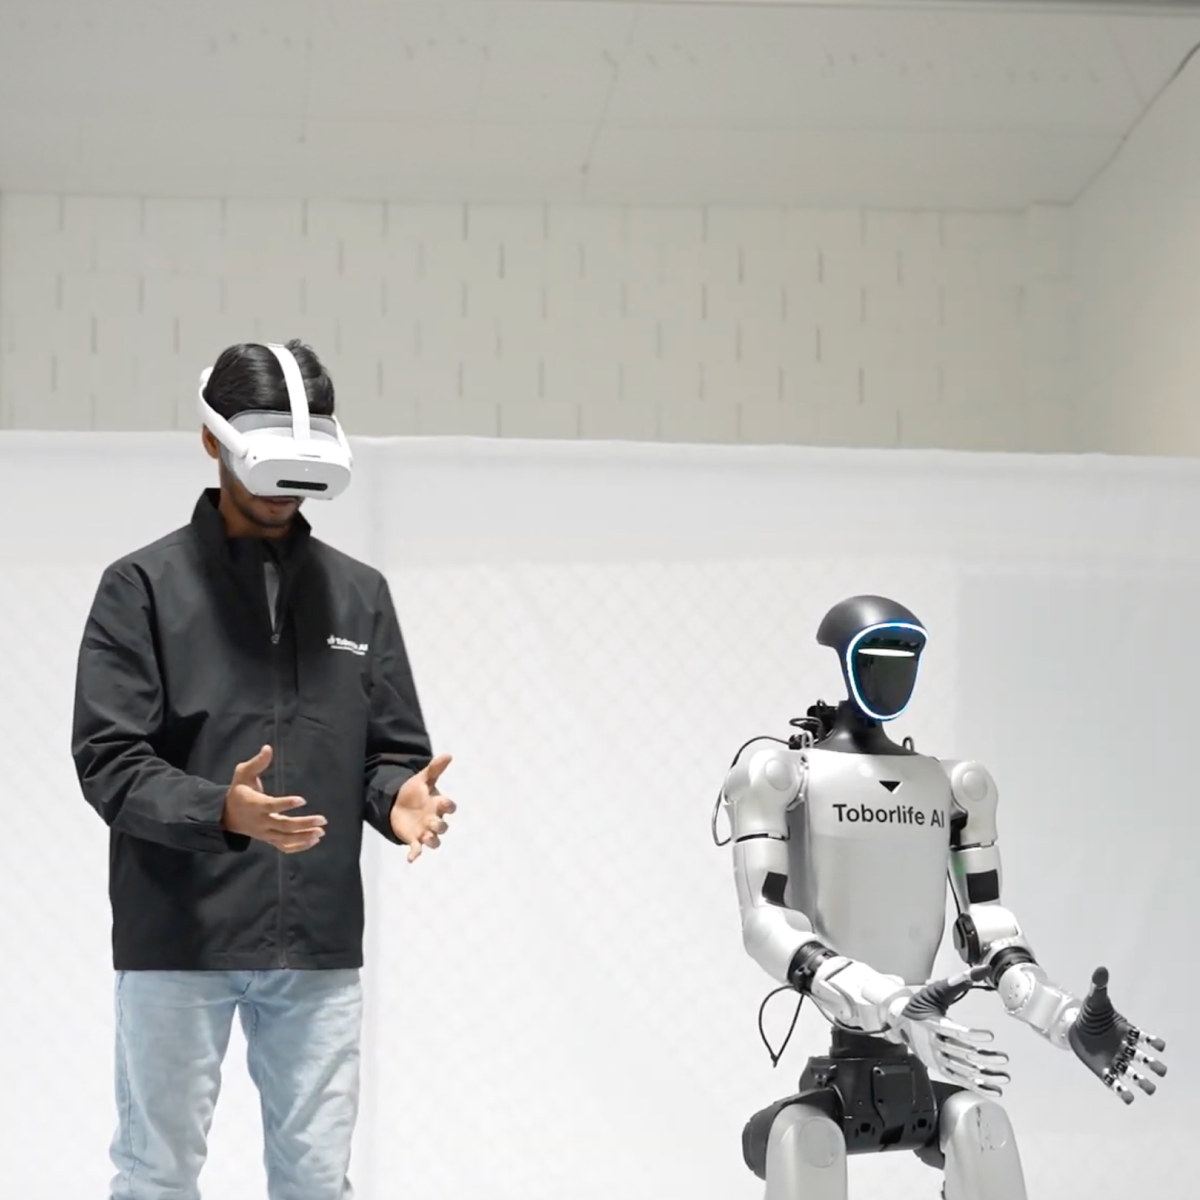

This bookmark explains how a Unitree teleoperation robot should be assessed by the quality of the session it produces. It covers operator input, camera feedback, robot state, timing, interventions, failures, and recorded outcomes. Save it for teams comparing teleoperated Unitree configurations for research, education, manipulation, or physical AI workflows. The summary also works for categorizing robotics resources without turning the bookmark into an ad.