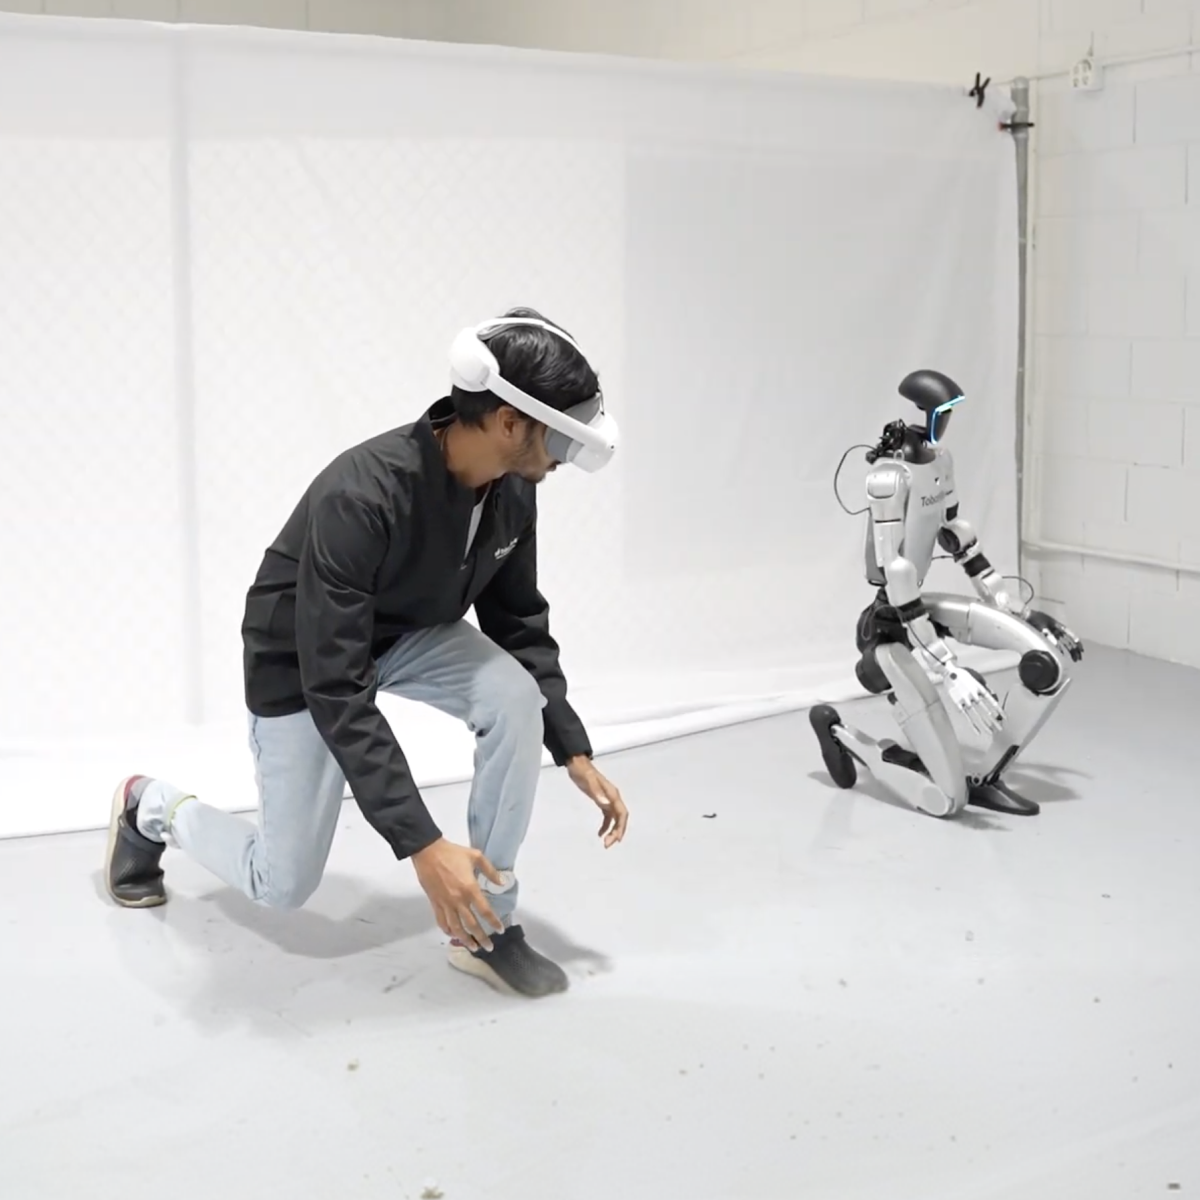

A Unitree teleoperation robot needs more than a network link because useful remote operation depends on video quality, control mapping, latency, local safety behavior, emergency stopping, and predictable recovery when communications degrade. The right architecture also changes with the robot’s form factor and task. Toborlife AI, the official partner of Unitree, provides technical context for teams evaluating teleoperated humanoids and quadrupeds across research, inspection, training, demonstration, and supervised field workflows.