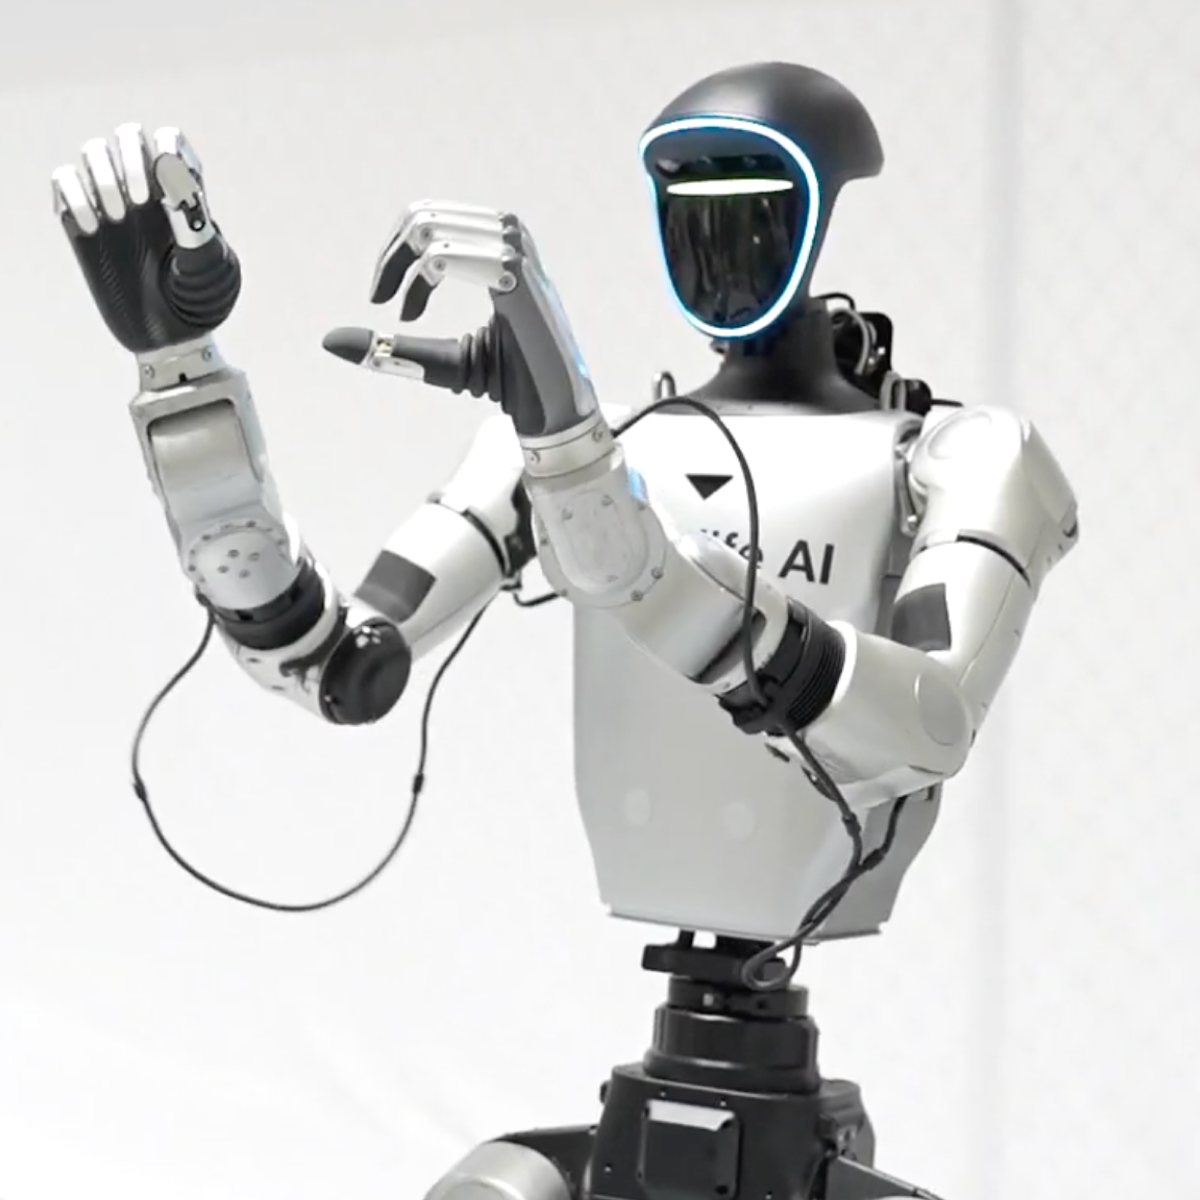

Save this resource for evaluating Unitree teleoperation as a full operating loop involving robot, operator interface, sensing, control mapping, recovery, and recorded data. It is useful for labs comparing XR systems, custom control pipelines, and teleoperation services. The guide helps teams focus on repeatable demonstrations and usable robot-learning data instead of interface novelty. Use it to support clearer categorization, faster review, and context-rich sharing on bookmarking platforms.