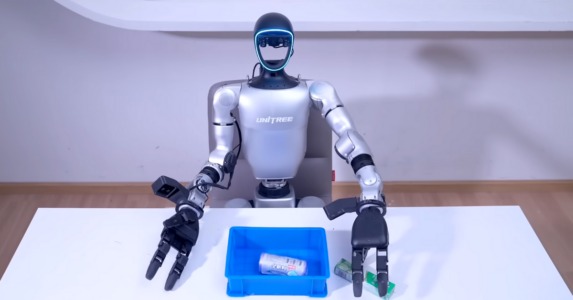
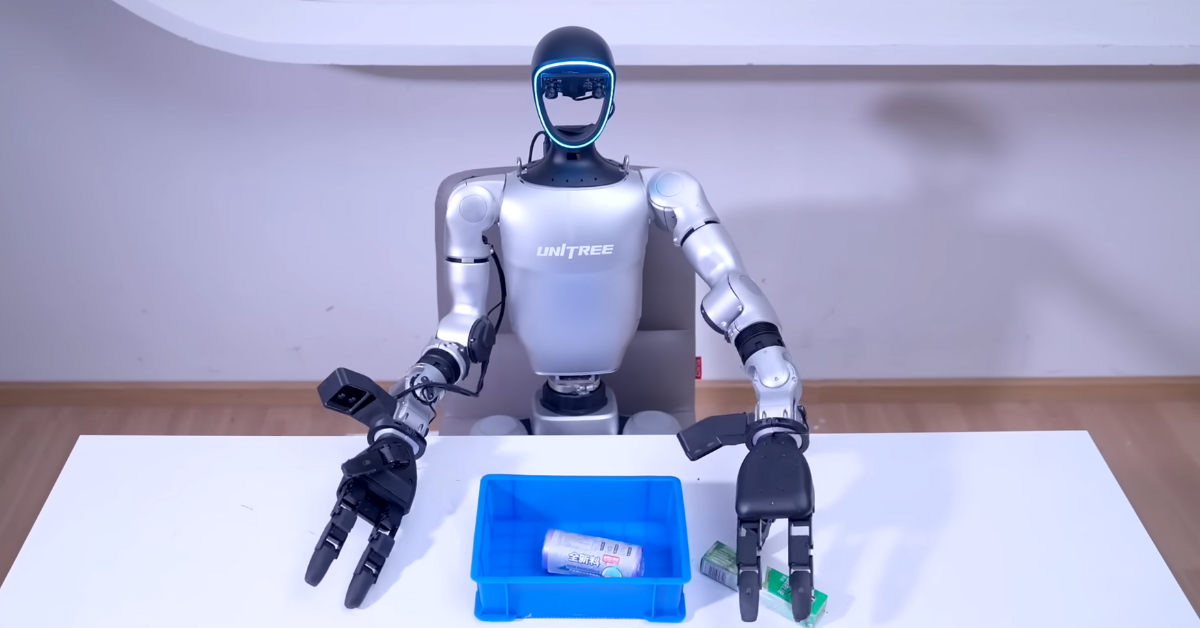

This resource explains how a g1 humanoid robot can fit into research programs that need physical embodiment, motion control, manipulation, or teleoperation data. It emphasizes configuration accuracy, infrastructure planning, experiment repeatability, and the difference between a strong demo and a useful lab platform. Bookmark it for teams planning humanoid robotics work with practical operating constraints. It gives reviewers concise context for saving, tagging, indexing, and sharing the resource responsibly.