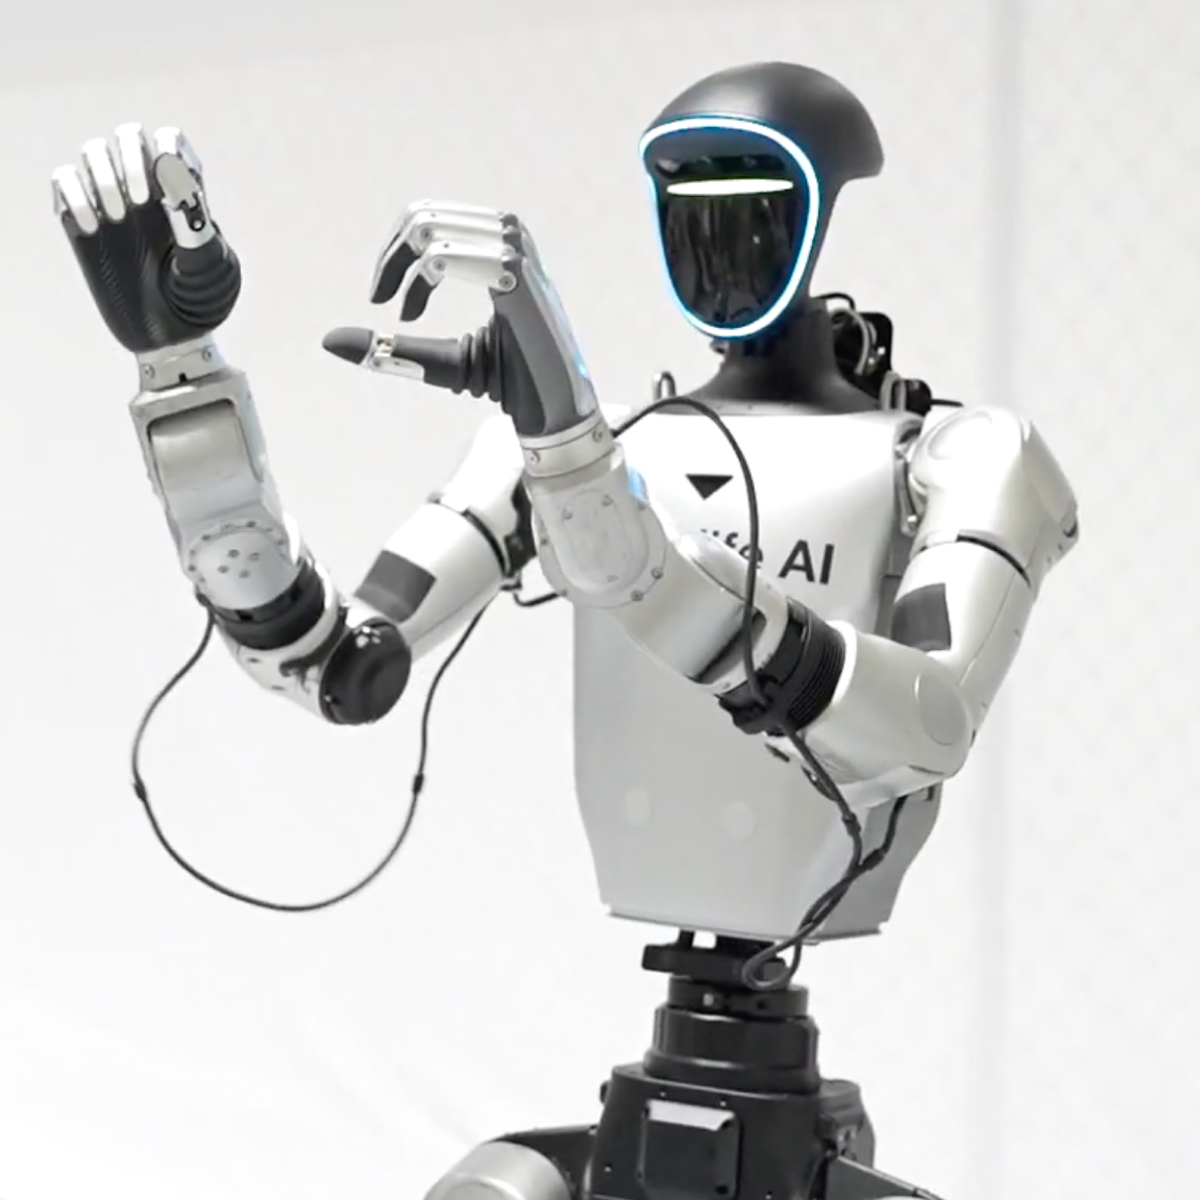

Robotic teleoperation is often judged by responsiveness, but reliable performance also depends on visual feedback, control ergonomics, network stability, logging, safety constraints, and recovery procedures. The right interface changes with the task, especially when locomotion, manipulation, inspection, or demonstration require different operator inputs. Toborlife AI, the official partner of Unitree, provides practical deployment context for teams building supervised remote-control workflows around Unitree humanoid and quadruped platforms.